3D Geodata Academy

LiDAR

Point cloud level of detail: octree render, coarse to fine

Point Cloud Level of Detail in Python: Octrees, Frustum Culling, and Out-of-Core Rendering

A cloud bigger than your memory still spins at sixty frames a second. The trick is the one your maps app already plays on you: a pyramid of pre-cut tiles, called an octree, that loads detail only where you are looking. Here is the full machinery, with a runnable Python demo.

Point Cloud Level of Detail in Python: Octrees, Frustum Culling, and Out-of-Core Rendering Read More »

3D Point Cloud Vectorization

Vectorization of 3D Point Cloud for LiDAR City Models

By Dr. Florent Poux, PhD in 3D geospatial sciences | Author, 3D Data Science with Python (O’Reilly) | Published 18 January 2024 3D Point Cloud Vectorization for LiDAR City Models This hands-on approach is standalone and covers the process of LiDAR Vectorization. We then focus on City Model Automatic Generation (LoD 0) in 5 main […]

Vectorization of 3D Point Cloud for LiDAR City Models Read More »

Data labelling

Free LiDAR point cloud for self-driving cars

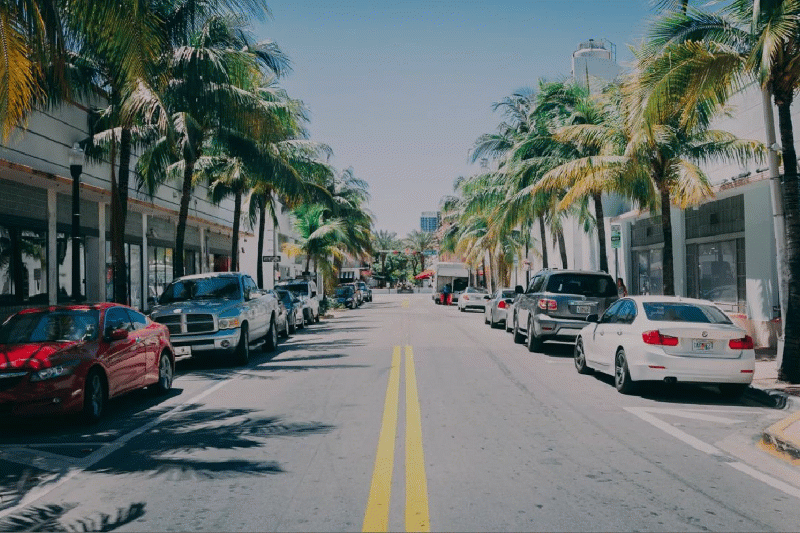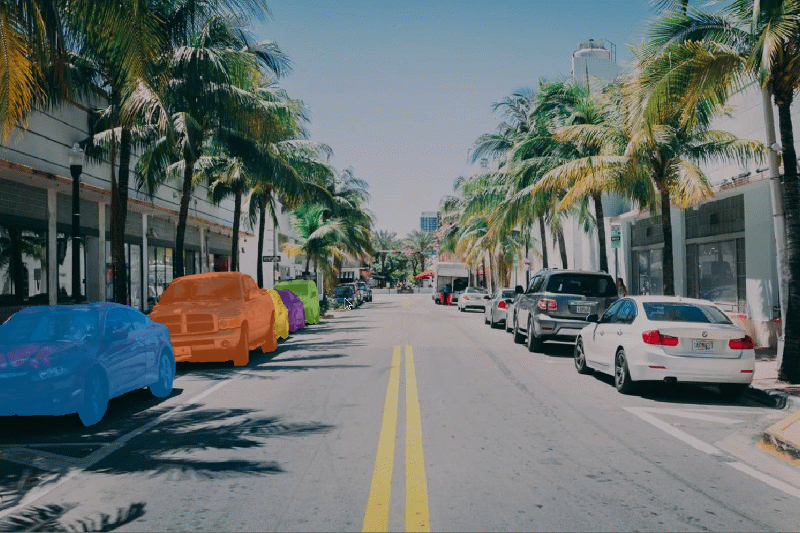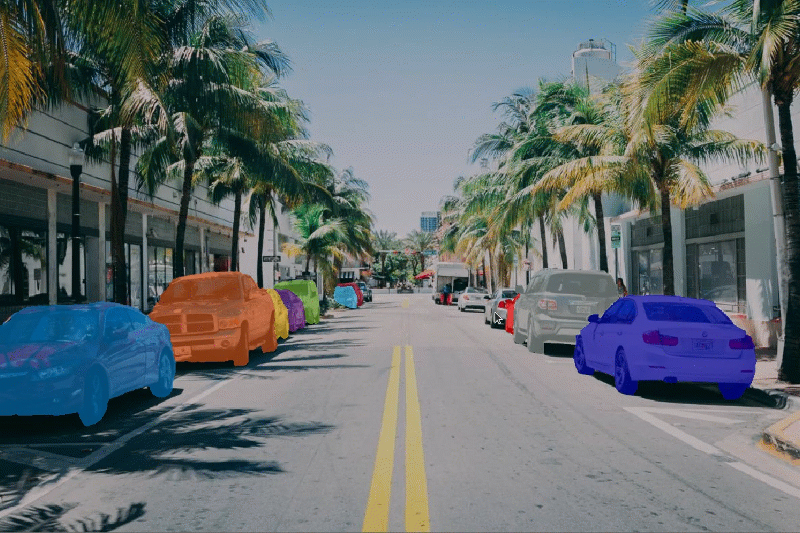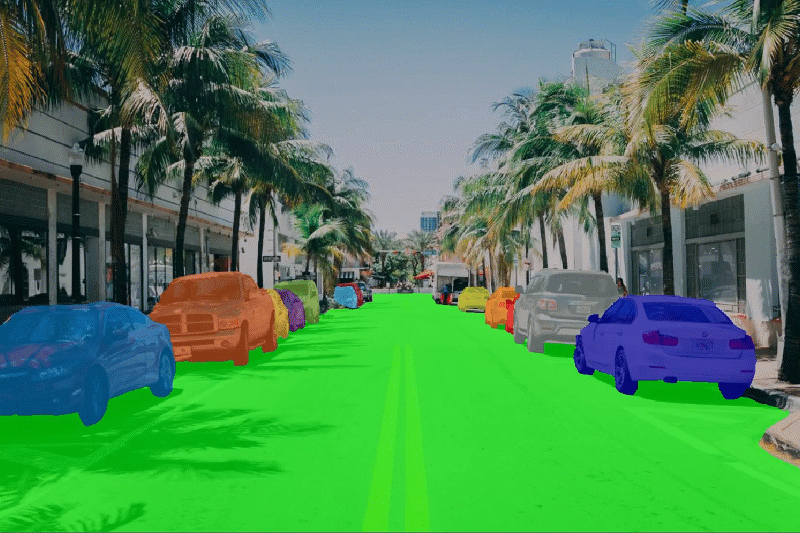
By Dr. Florent Poux, PhD in 3D geospatial sciences | Author, 3D Data Science with Python (O’Reilly) | Published 9 December 2020 Scale AI released a new LiDAR point cloud dataset, and accelerate the growth of Autonomous Driving research. Point Cloud Data labelling Data labelling, also called data annotation/tagging/classification, is the process of tagging (i.e. […]

Free LiDAR point cloud for self-driving cars Read More »

Scroll to Top