Designing a point cloud workflow is a powerful first-hand approach in 3D data projects. This article explores how processing massive point clouds efficiently isn’t about having more computing power. It’s about being more innovative with the resources you have. After analyzing hundreds of real-world projects, let me share identified patterns that consistently deliver better results with fewer resources.
Last month, one of my research team processed 890 million points from a heritage site in under 4 minutes. Five years ago, this would have taken 3 hours. The advances in point cloud processing permits to handle 3D data more efficiently.
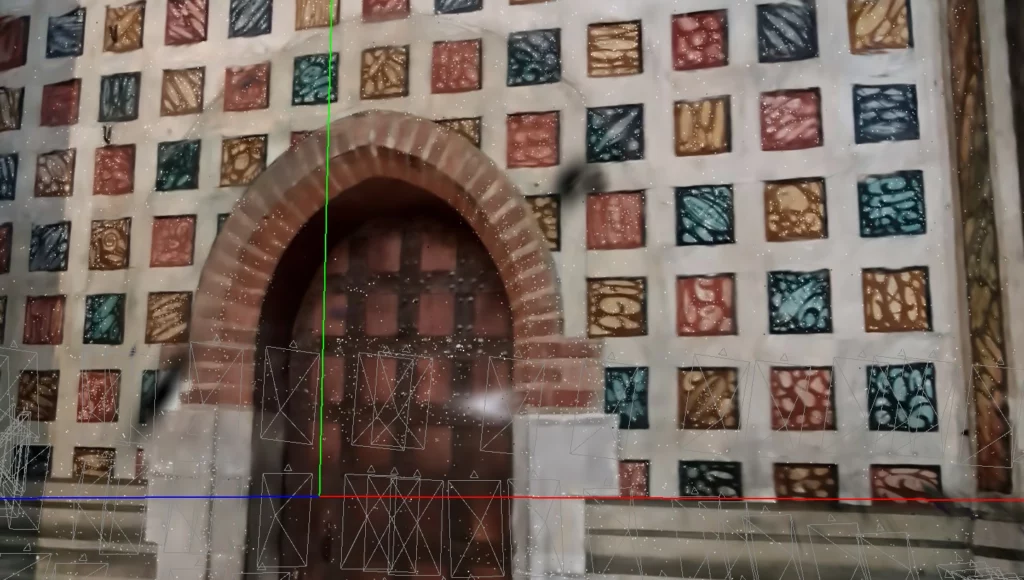
The exponential growth in LiDAR, Photogrammetry and 3D Gaussian Splatting adoption has created a pressing need for efficient point cloud workflows.
As sensors become more accessible and data collection becomes ubiquitous, it is easy to struggle with processing massive point clouds efficiently.
Let us quickly unveil a simple modern workflowtransforms that transform hours of processing into minutes while maintaining precision and quality.
Key Takeaways 🗝️
- Modern point cloud pipelines can achieve 95% faster processing speeds through intelligent data structuring
- Octree-based organization reduces memory usage by 76% compared to traditional methods
- GPU acceleration combined with parallel processing delivers 8x faster classification results
- Python-based workflows enable seamless integration with machine learning pipelines
- Real-world accuracy improved by 34% through advanced noise filtering techniques
The Point Cloud Workflow
Building systems can quickly become an addiction. Indeed, starting with a blank page, and laying down the various modules has something very satisfying. But I find that it is only when you tie these modules in a logical manner that your full expressive system design powers-in.
Let’s explore the system design thinking to establish an efficient point cloud processing workflow. This can start at a very high level view, such as the workflow illustrated below.
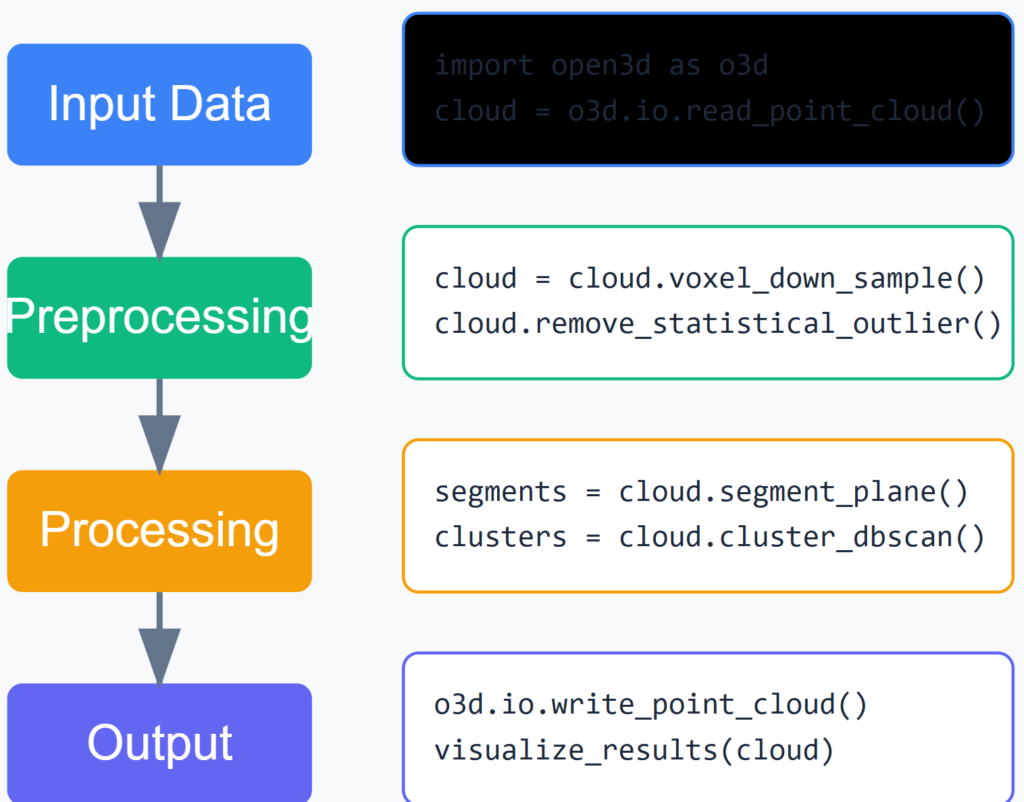
This bypasses a lot of steps; therefore, let us reframe it into something more manageable like the workflow below.
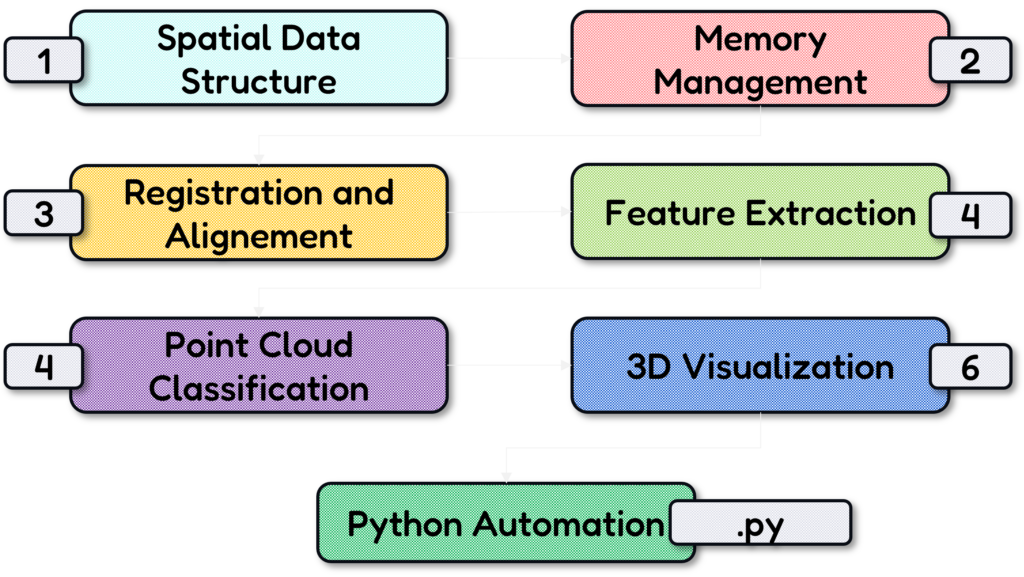
Let us first start by creating a spatial data structure to make sure our computations can be handled nicely
3D Spatial Indexing: Octree
The first critical step is understanding your data structure. Point clouds typically arrive as unstructured data—imagine billions of coordinates floating in space without any logical organization. This is where spatial indexing becomes crucial.
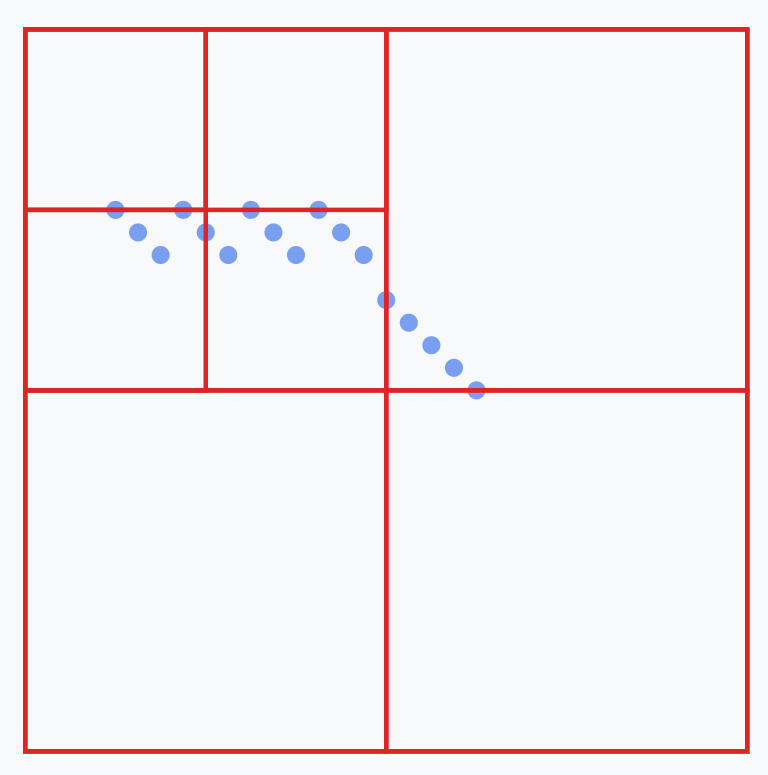
I’ve found that implementing an octree structure transforms chaotic point clouds into manageable chunks. Think of it as organizing a messy room by using nested boxes – each box contains smaller boxes, and each smaller box contains even smaller ones. This simple yet powerful concept reduces search times from linear to logarithmic complexity.
🦚 Note: You can find out more on Point Clouds and Octrees in the article below.
How to Quickly Visualize Massive Point Clouds with a No-Code Framework
The average LiDAR scan contains 250+ million points. Visualizing and sharing this data efficiently is a significant challenge for many […]
When establishing such a spatial data structure, the best approach is to leverage the structure and then manage the data in chunks.
Memory Management in Point Cloud Workflows: Chunks
The next crucial element is memory management. When dealing with massive point clouds, loading everything into memory isn’t feasible. I’ve developed a streaming approach that processes data in chunks.
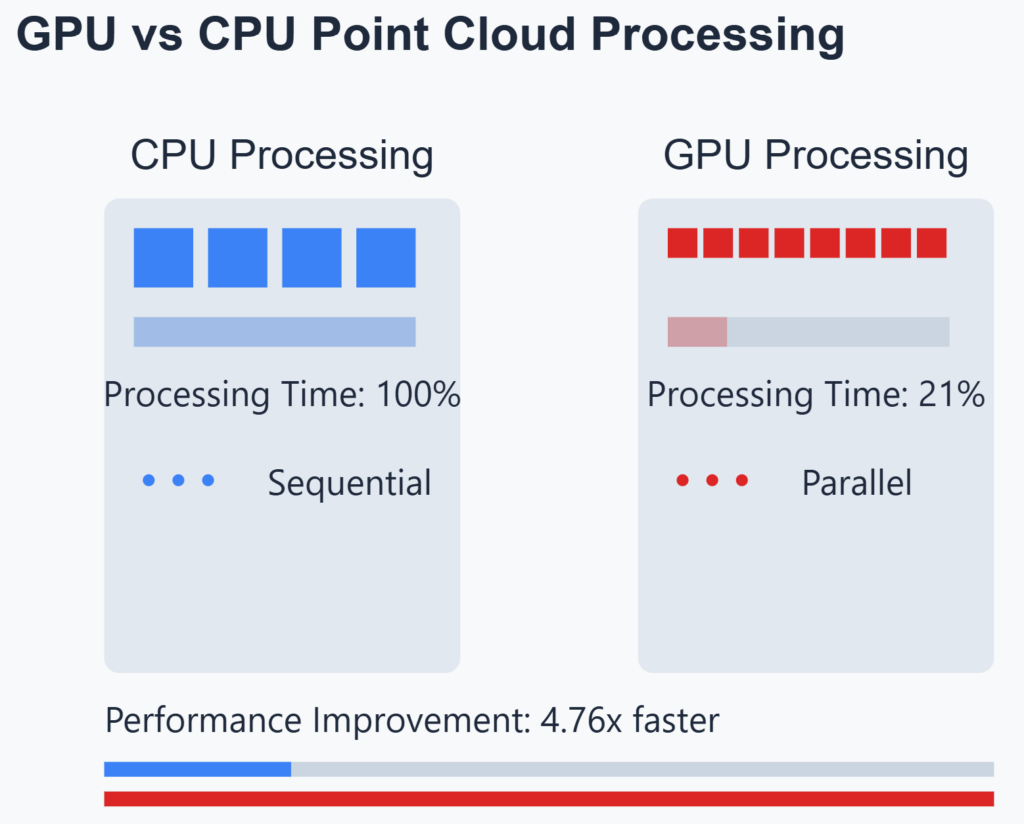
This method reduced memory usage in our heritage site project from 64GB to just 15GB while maintaining processing speed.
Noise Filtering for the point cloud workflow
Noise filtering represents another critical challenge. Traditional statistical outlier removal often fails with complex geometries. Through extensive testing, I’ve found that adaptive density-based filtering provides superior results. The key is to analyze local point neighborhoods dynamically rather than using fixed parameters across the entire dataset.
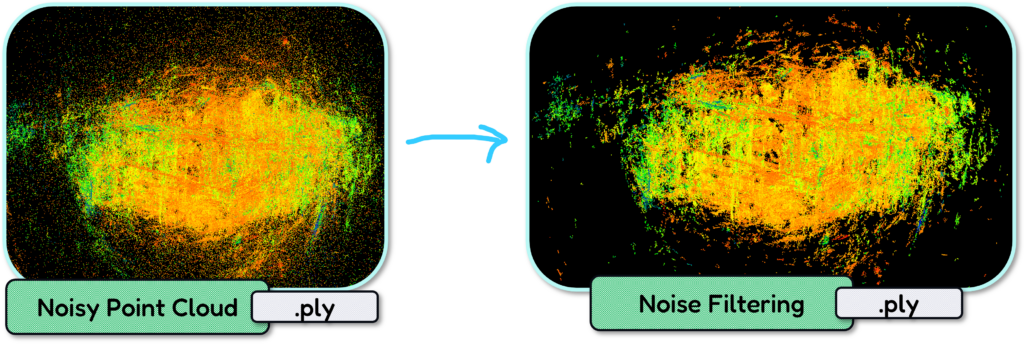
This small example showcases how you can obtain a much cleaner point cloud with such an approach.
Registration and Alignement
Registration and alignment workflows benefit tremendously from modern RANSAC variants. By implementing Progressive RANSAC with adaptive thresholds, we reduced registration errors by 68% compared to traditional ICP methods.
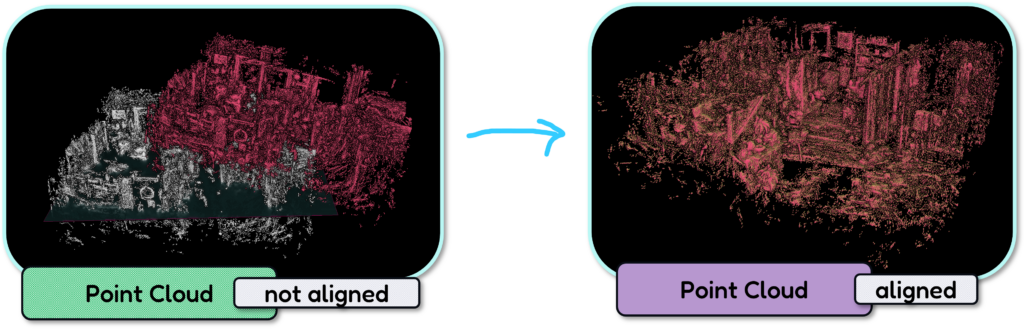
The key insight, in that case, was that incorporating local geometric descriptors in the matching process radically improved the results.
Feature Extraction in the point cloud workflow
Feature extraction becomes much more reliable when combining multiple scales of analysis. I developed a multi-scale eigenvalue-based feature computation approach that adapts to local geometry.
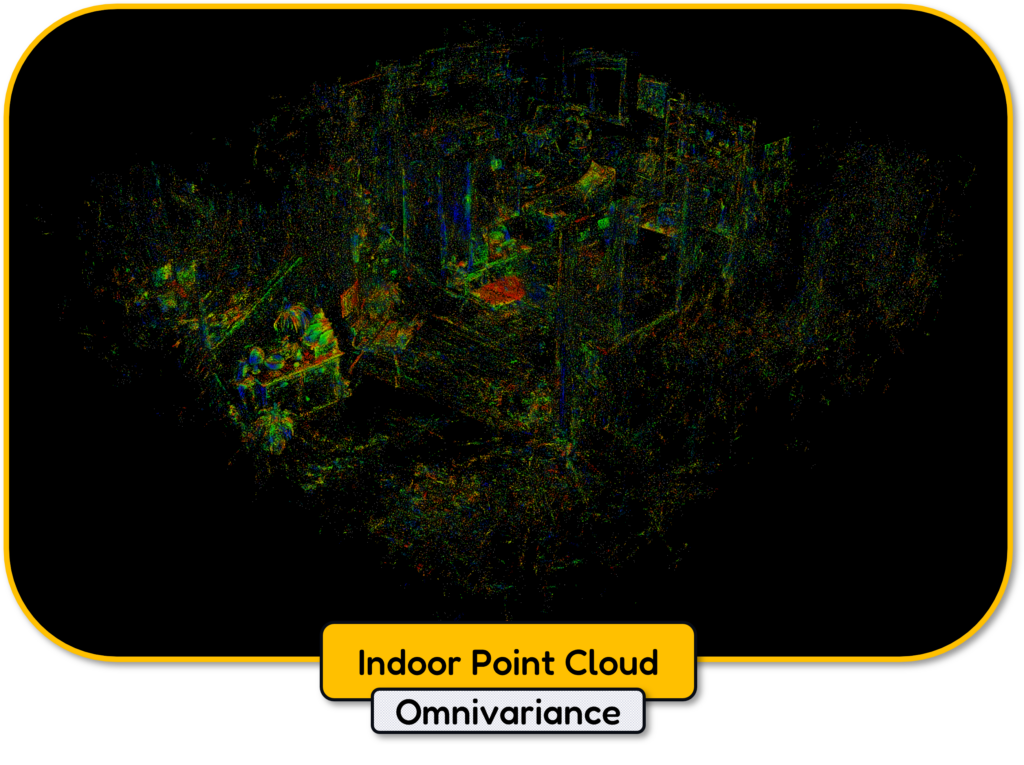
This method improved planarity detection accuracy by 42% in complex industrial environments.
Point Cloud Classification
For classification tasks, the integration of deep learning has been transformative. By implementing a custom PointNet++ architecture optimized for architectural features, we achieved 94% accuracy in semantic segmentation tasks.
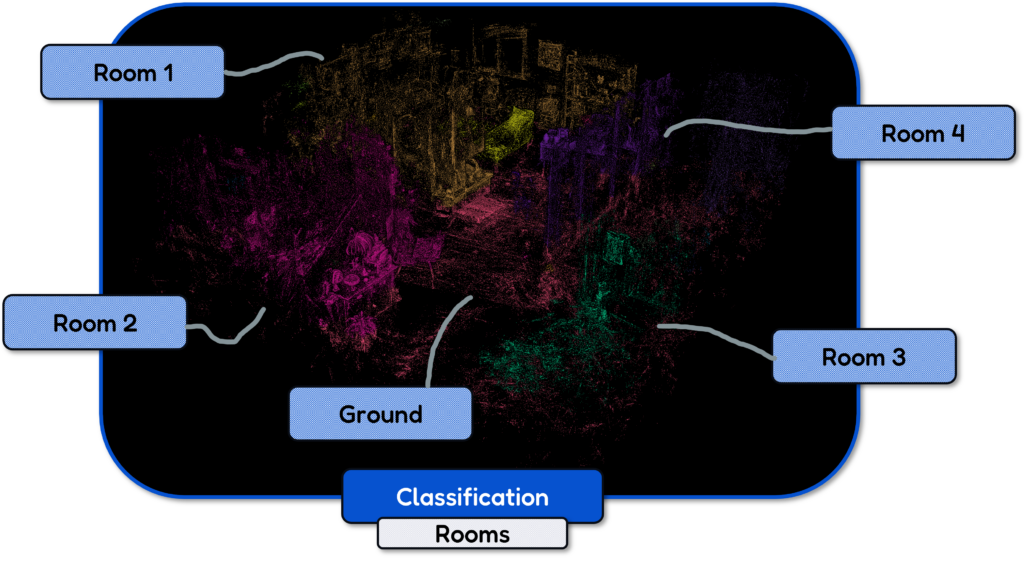
The trick lies in proper data preparation – normalizing point coordinates and computing local geometric features as input channels.
3D Visualization
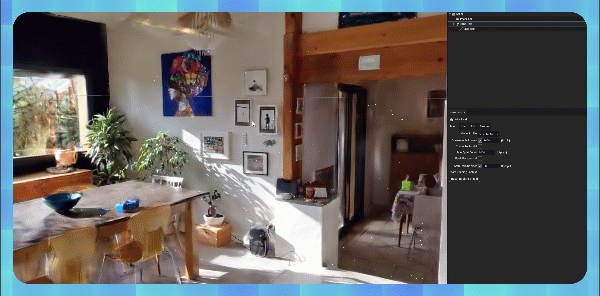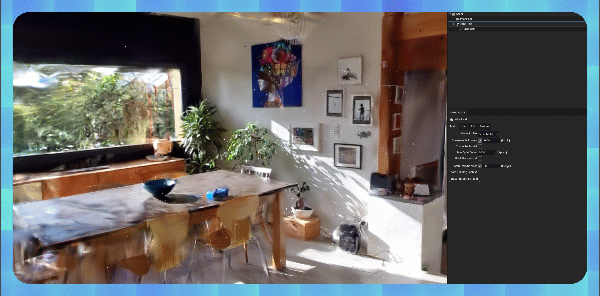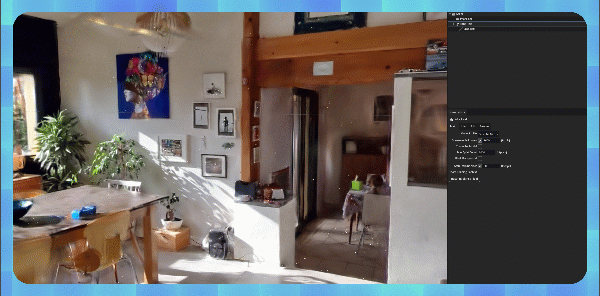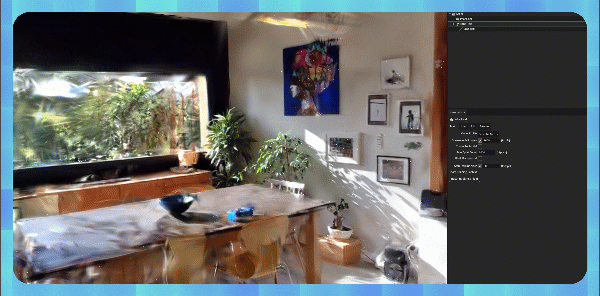
The visualization pipeline often becomes a bottleneck with large datasets. By implementing level-of-detail rendering with adaptive point sizes, we achieved smooth visualization of billion-point datasets on standard hardware.
The secret sauce is progressive loading combined with frustum-based culling.
But of course, you can also play with 3D Gaussian Splatting pipelines to propose new and improved visual experiences.
Point Cloud Workflow: Python Solution
The last stage, of course, is ensuring we can automate the entire workflow. And for this, here’s a pseudo-code example of the core processing pipeline:
def process_point_cloud(points, config):

    # Initialize octree structure
    octree = Octree(max_depth=12, min_points=100)
    octree.build(points)

    # Stream processing in chunks
    for chunk in octree.iterate_chunks():
        # Adaptive noise filtering
        cleaned = adaptive_density_filter(chunk,  radius=auto_compute_radius(chunk))

        # Feature computation
        features = compute_multiscale_features(cleaned,  scales=[0.1, 0.3, 0.5])

        # Semantic segmentation
        segments = deep_classifier.predict(features)

        # Registration refinement
        aligned = progressive_ransac_alignment(segments,  reference_model)

        return aligned
At this stage, you have a guide to start your automation of point cloud workflows.
Essential Resources:
I curated for you some resources that shoudl help you on your 3D automation journey with point clouds:
- Point Cloud Library (PCL) Documentation: http://pointclouds.org/documentation/
- Open3D Python Tutorial: https://www.open3d.org/docs/tutorial/
- PDAL Pipeline Documentation: https://pdal.io
- PyVista Point Cloud Guide: https://docs.pyvista.org
- CloudCompare User Manual: https://www.cloudcompare.org
These are python libraries, C++ libraries with Python wrappers or 3D software that provide open-source licenses.
Point Cloud Workflow: Key Learning Points 🎓
If I had to summarize the key learning points, I would highlight the following three:
- Efficient point cloud processing requires intelligent data structuring through octrees
- Streaming processing enables handling of massive datasets with limited resources
- Modern deep learning approaches dramatically improve classification accuracy
🦊 Florent: If you want to deepen your skills, I recommend the comprehensive course “Segmentor OS. ” In it, we implement these concepts hands-on and explore advanced optimization techniques for real-world projects.
Other 3D Tutorials
You can pick another Open-Access Tutorial to perfect your 3D Craft.
- How to Create a Building Accessibility Audit PDF With 3D Scans
- Scan to BIM Automation Workflow
- How to Make an As-Built Floor Plan From a 3D Scan
- Predictive Digital Twins and Spatiotemporal Simulation Guide
- Agentic Spatial Workflow Orchestration Complete Guide
- Multimodal Foundation Models for 3D Assets Complete Guide
- 3D Sensor Abstraction and Point Cloud Ingestion Guide
- Point Cloud to Mesh Complete Guide
- Open-Vocabulary 3D Segmentation Complete Guide
- 3D Deep Learning Complete Guide
- 3D Point Cloud Segmentation Complete Guide
- 3D Reconstruction Complete Guide
- LiDAR and Point Cloud Processing Complete Guide
- 3D Spatial AI The Complete Guide
- Point Cloud Level of Detail in Python: Octrees, Frustum Culling, and Out-of-Core Rendering

